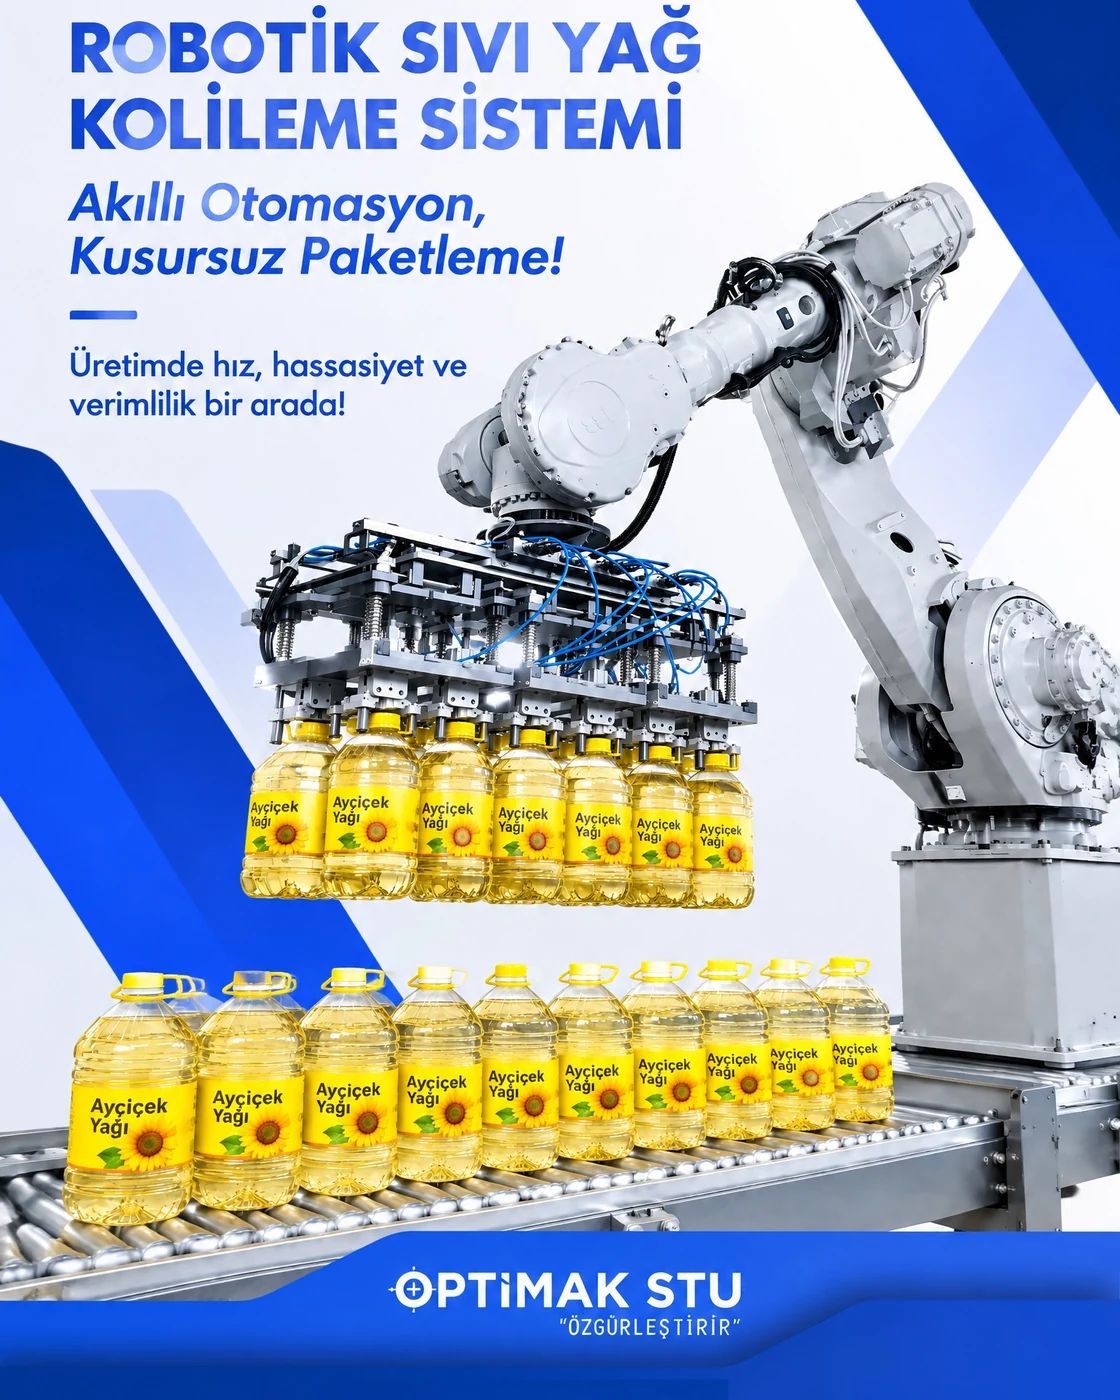
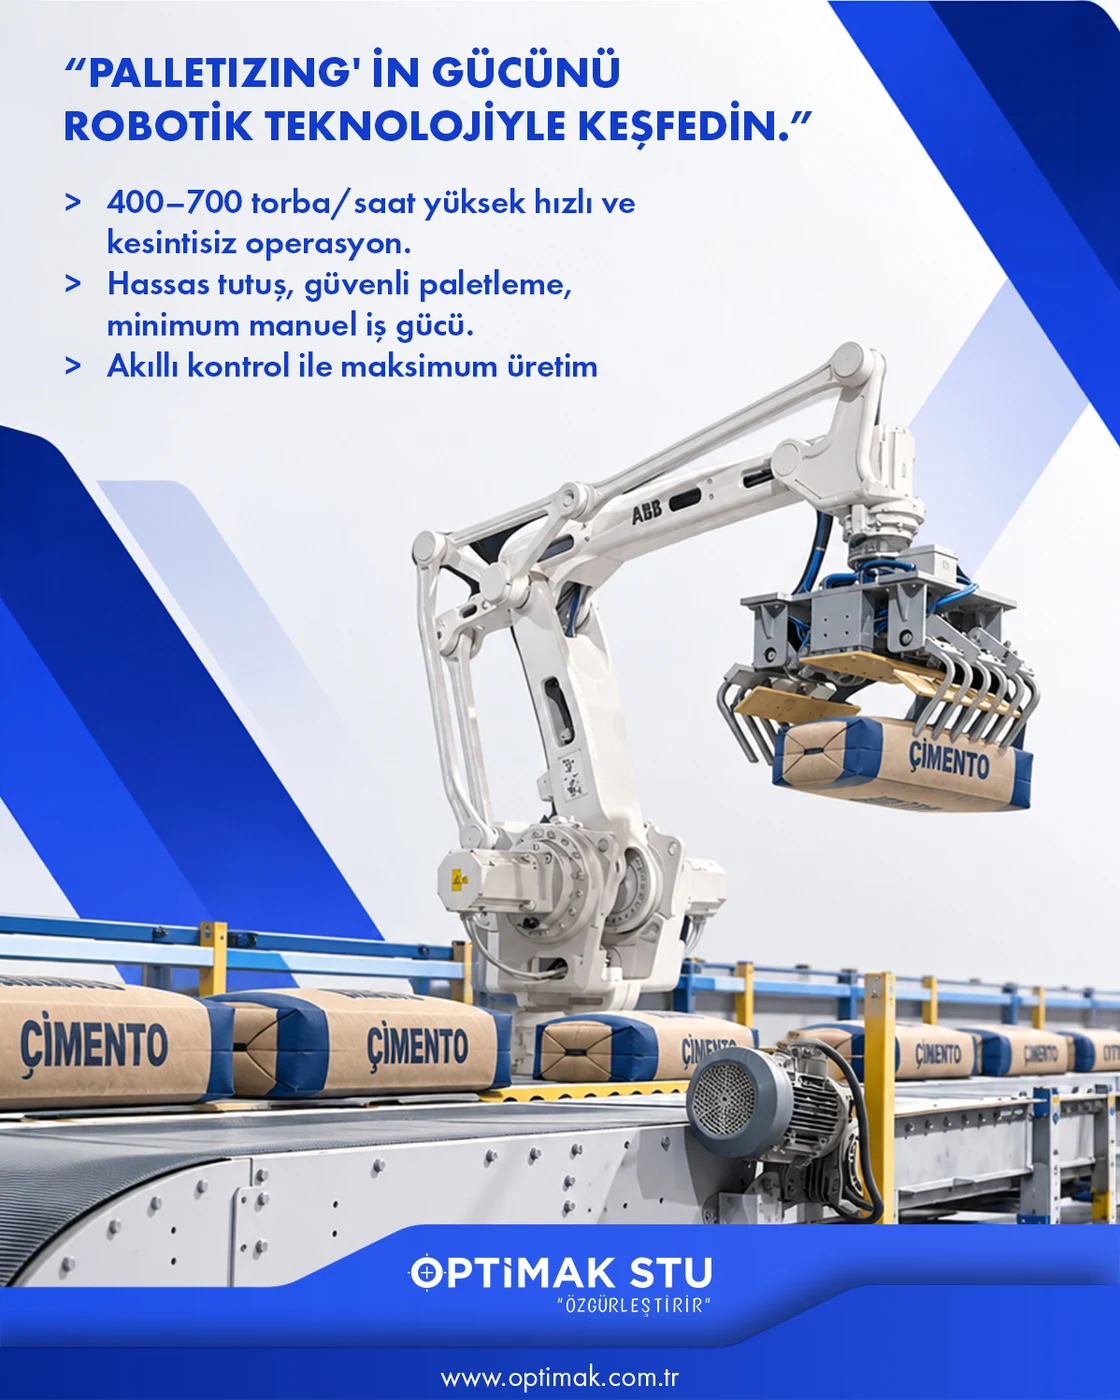
Optimak STU’s robotic palletizing post dated 17 September 2026 explained a system approach for demanding heavy-bag handling operations. The use of mechanical or pneumatic gripper solutions selected according to the product’s characteristics was one of the presentation’s key points.
The automation architecture, controlled through PLC and HMI, is presented alongside the controlled transfer of bags and their placement in the pallet pattern. The post highlights the goals of reducing manual handling and making end-of-line operations more orderly.